McCue, Leigh, Bagheri, Shaghayegh, Wright, Leanne, and Hicks, Kevin, “Reconciling innovation and safety for additive manufacturing in academia,” 2026 ASEE Annual Conference & Exposition, Charlotte, NC, June, 2026
Author Archives: Leigh
Work-in-Progress: Nurturing Innovation in Agriculture, Forestry, and Fishing Occupational Safety
McCue, L, Milkovich, P, Geraghty, E., Hirabayashi, L., Sorensen, J. and Davis, F., “Work-in-Progress: Nurturing Innovation in Agriculture, Forestry, and Fishing Occupational Safety,” 2025 ASEE Annual Conference & Exposition, Montreal, Canada, June, 2025
Transferable eye gaze control method for maritime vehicles as demonstrated on an unmanned surface vessel (USV)
Barth, V., Jones, V., and McCue, L., “Transferable eye gaze control method for maritime vehicles as demonstrated on an unmanned surface vessel (USV),” 2025 Symposium on Eye Tracking Research and Applications (ETRA ’25), May 26–29, 2025, Tokyo, Japan, https://doi.org/10.1145/3715669.3723127
Work-in-progress: A data gathering effort on STEM versus non-STEM faculty for assessing equity in recruitment, retention, and promotion at a large R1 institution
Wonch Hill, Patricia, Patrick Healey, Milagros Rivera, Tehama Lopez-Bunyasi, Girum Urgessa, Leigh McCue, and Supriya Baily, “Work-in-progress: A data gathering effort on STEM versus non-STEM faculty for assessing equity in recruitment, retention, and promotion at a large R1 institution” 2024 ASEE Annual Conference and Exposition, Portland, Oregon, June, 2024
A University-County Collaboration to Excite Students about Citizen Science with Maritime Robotics
McCue, L., Bell, W., and Foster, E., “A University-County Collaboration to Excite Students about Citizen Science with Maritime Robotics,” 2024 ASEE Annual Conference and Exposition, Portland, Oregon, June, 2024.
Work-in-progress: A data gathering effort on STEM faculty startup packages for assessing equity in recruitment
McCue, L., Urgessa, G., Lopez Bunyasi, T., Healey, P., Hill, P., Lester, J., and Rivera, M., “Work-in-progress: A data gathering effort on STEM faculty startup packages for assessing equity in recruitment,” Minorities in Engineering Division, American Society for Engineering Education Annual Conference, Baltimore, MD, June, 2023.
Lessons learned in the development of a STEM outreach program for biologically inspired underwater robotics
McCue, L., Hagarty, A., Nelson, J., Nowzari, C., Raz, A., Rosenberg, J., Shishika, D., Smith, C., Yang, J., “Lessons learned in the development of a STEM outreach program for biologically inspired underwater robotics,” Ocean and Marine Engineering Division, American Society for Engineering Education Annual Conference, Baltimore, MD, June, 2023.
Incubating a Fisherman’s Intervention Idea: An Ergonomic Evaluation of Worker Modified Knives Used for Scalloping
Kim, J. H., Davis, F., Chen, Y., Hirabayashi, L., Milkovich, P., McCue-Weil, L., & Sorensen, J. (2026). Incubating a Fisherman’s Intervention Idea: An Ergonomic Evaluation of Worker Modified Knives Used for Scalloping. Journal of Agromedicine, 1–9. https://doi.org/10.1080/1059924X.2026.2719681.
Navigating the “Valley of Death”: A brief report on how incubators can nurture transition of research to practice to benefit worker wellbeing
Milkovich, Pamela J., Leigh McCue, Liane Hirabayashi, Andres Esteban Sandi Espejo, Lance Maben, Julie A. Sorensen, “Navigating the “Valley of Death”: A brief report on how incubators can nurture transition of research to practice to benefit worker wellbeing,” Journal of Agromedicine, Vol 30, Issue 3, 2025, pp. 423-429, https://doi.org/10.1080/1059924X.2025.2474711.
Beneath the Surface: Mental Health in Commercial Fisheries
Roome, AB, K Gertz, M Pain, H Sulman, J Graham, B Quinn, R Weil, L Kincl, J Dzugan, L McCue-Weil, P Jenkins, J Sorensen, “Beneath the Surface: Mental Health in Commercial Fisheries,” Journal of Agromedicine, Vol 30, Issue 3, 2025, pp. 417–422. https://doi.org/10.1080/1059924X.2025.2485930.
Adding insult to injury: the impact of musculoskeletal pain on fishermen’s sleep patterns
Sorensen, J., Jenkins, P., Gertz, K., Roome, A., Weil, R., Graham, J., Quinn, B., Kincl, L., Dzugan, J., McCue-Weil, L., “Adding insult to injury: the impact of musculoskeletal pain on fishermen’s sleep patterns,” Journal of Agromedicine, https://doi.org/10.1080/1059924X.2025.2451625, 2025.
On the Role of Capstone Design in Building the Naval Workforce
Kathir, N., Gallo, R., Knudsen, E., Amiri, M., Pulipaka, A., Barton, O., and McCue, L., “On the Role of Capstone Design in Building the Naval Workforce,” Naval Engineers Journal, December 2023.

Lab spirit
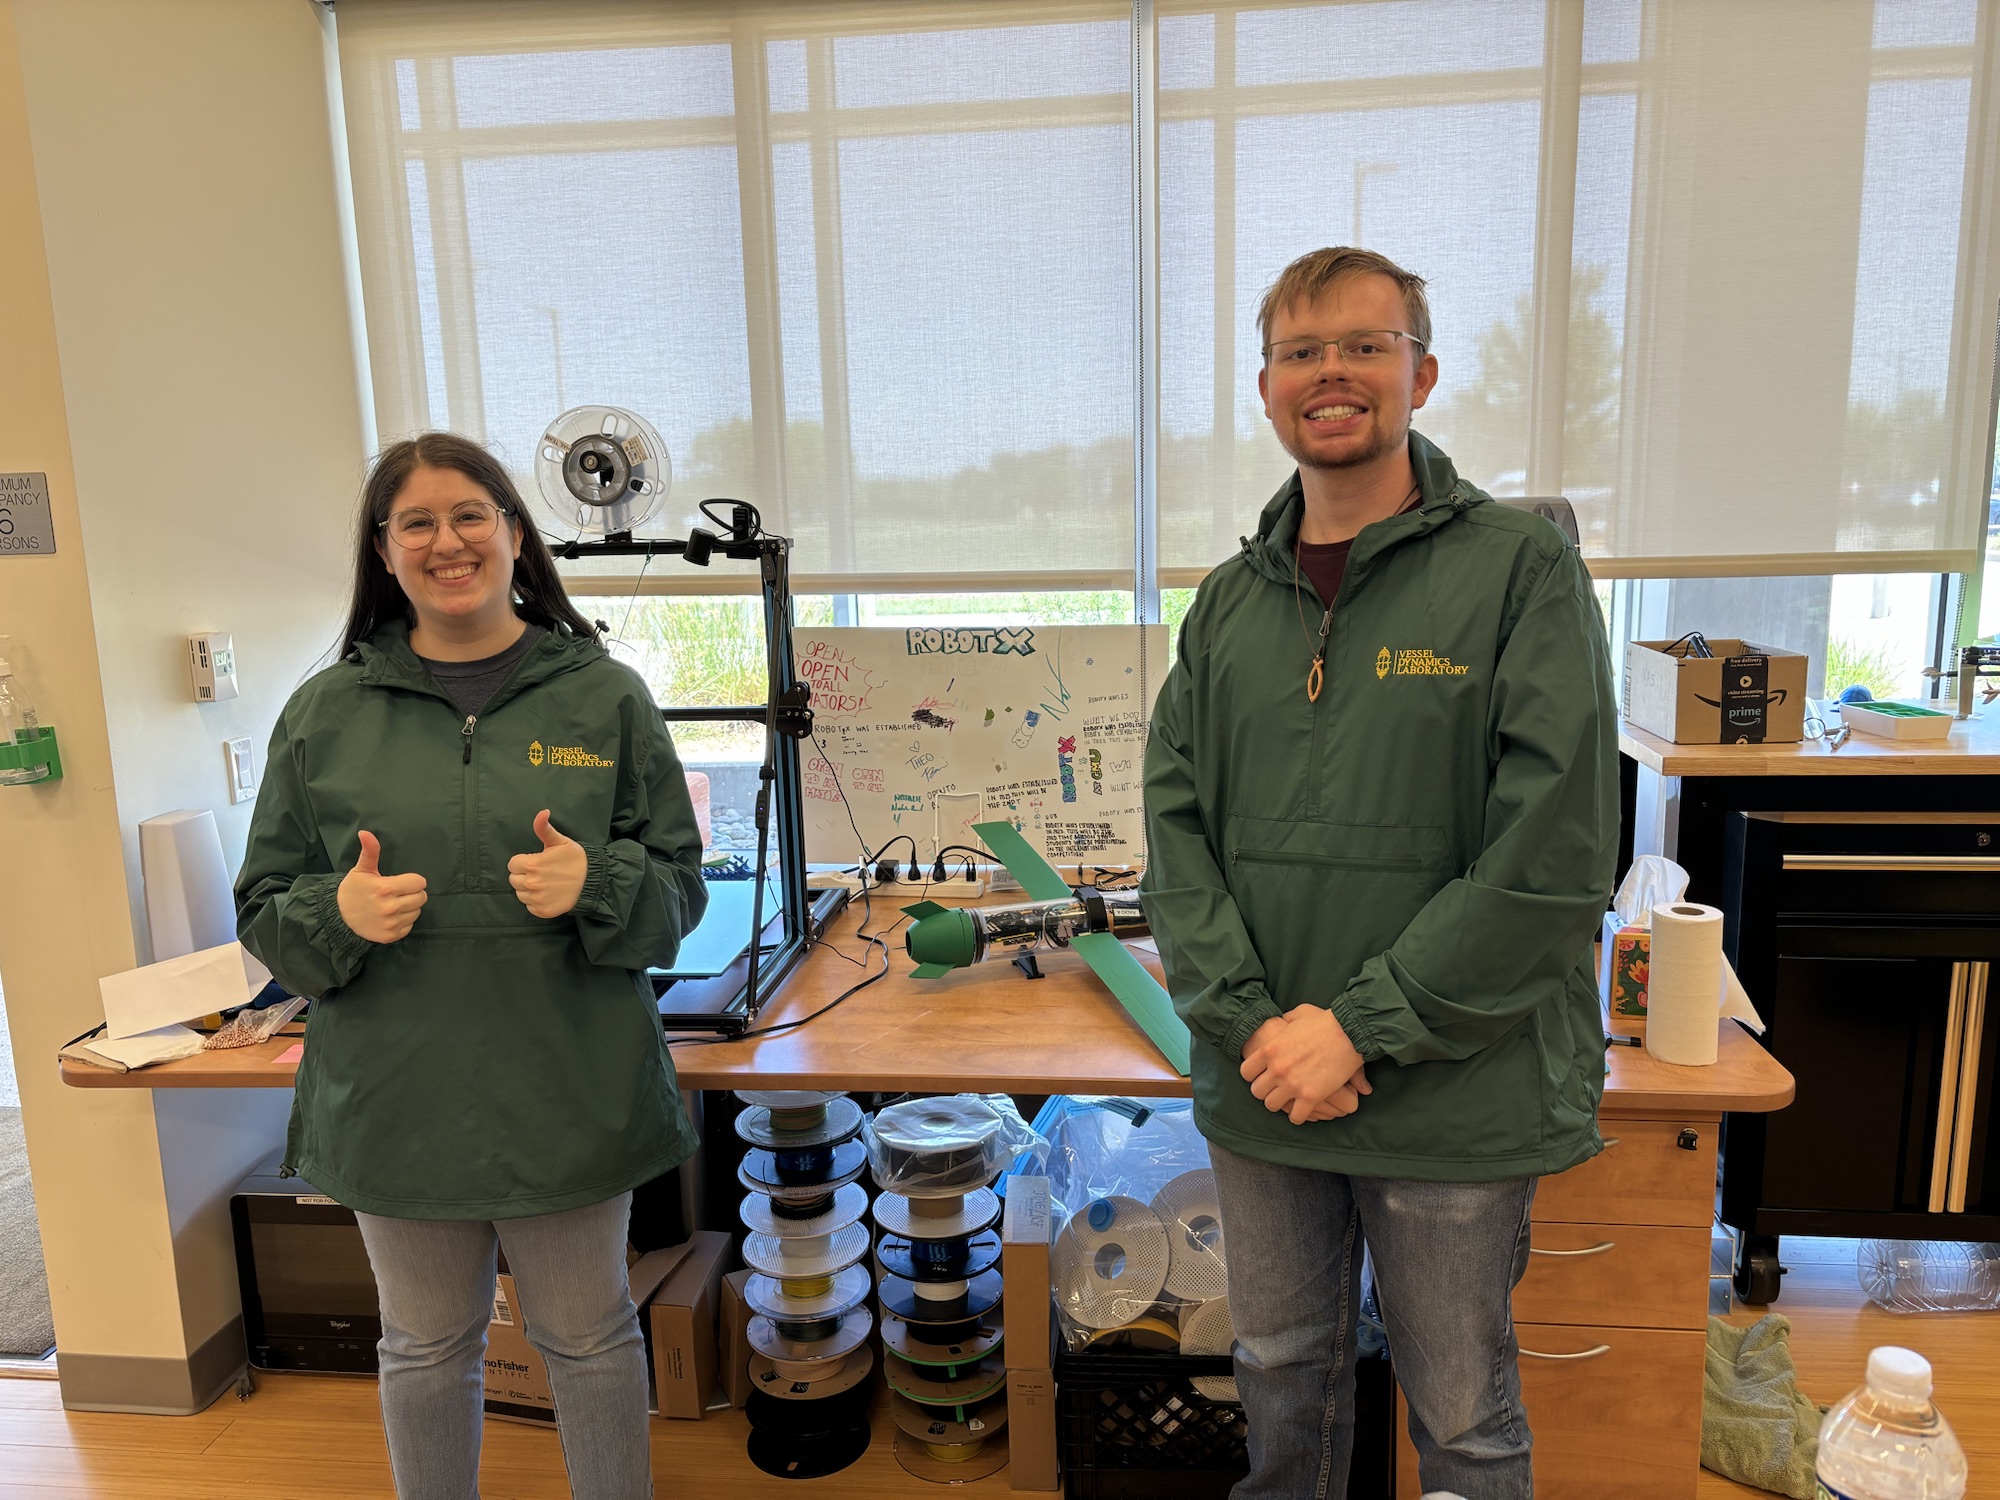
It’s been rainy…and we work on water…lab raincoats were inevitable!

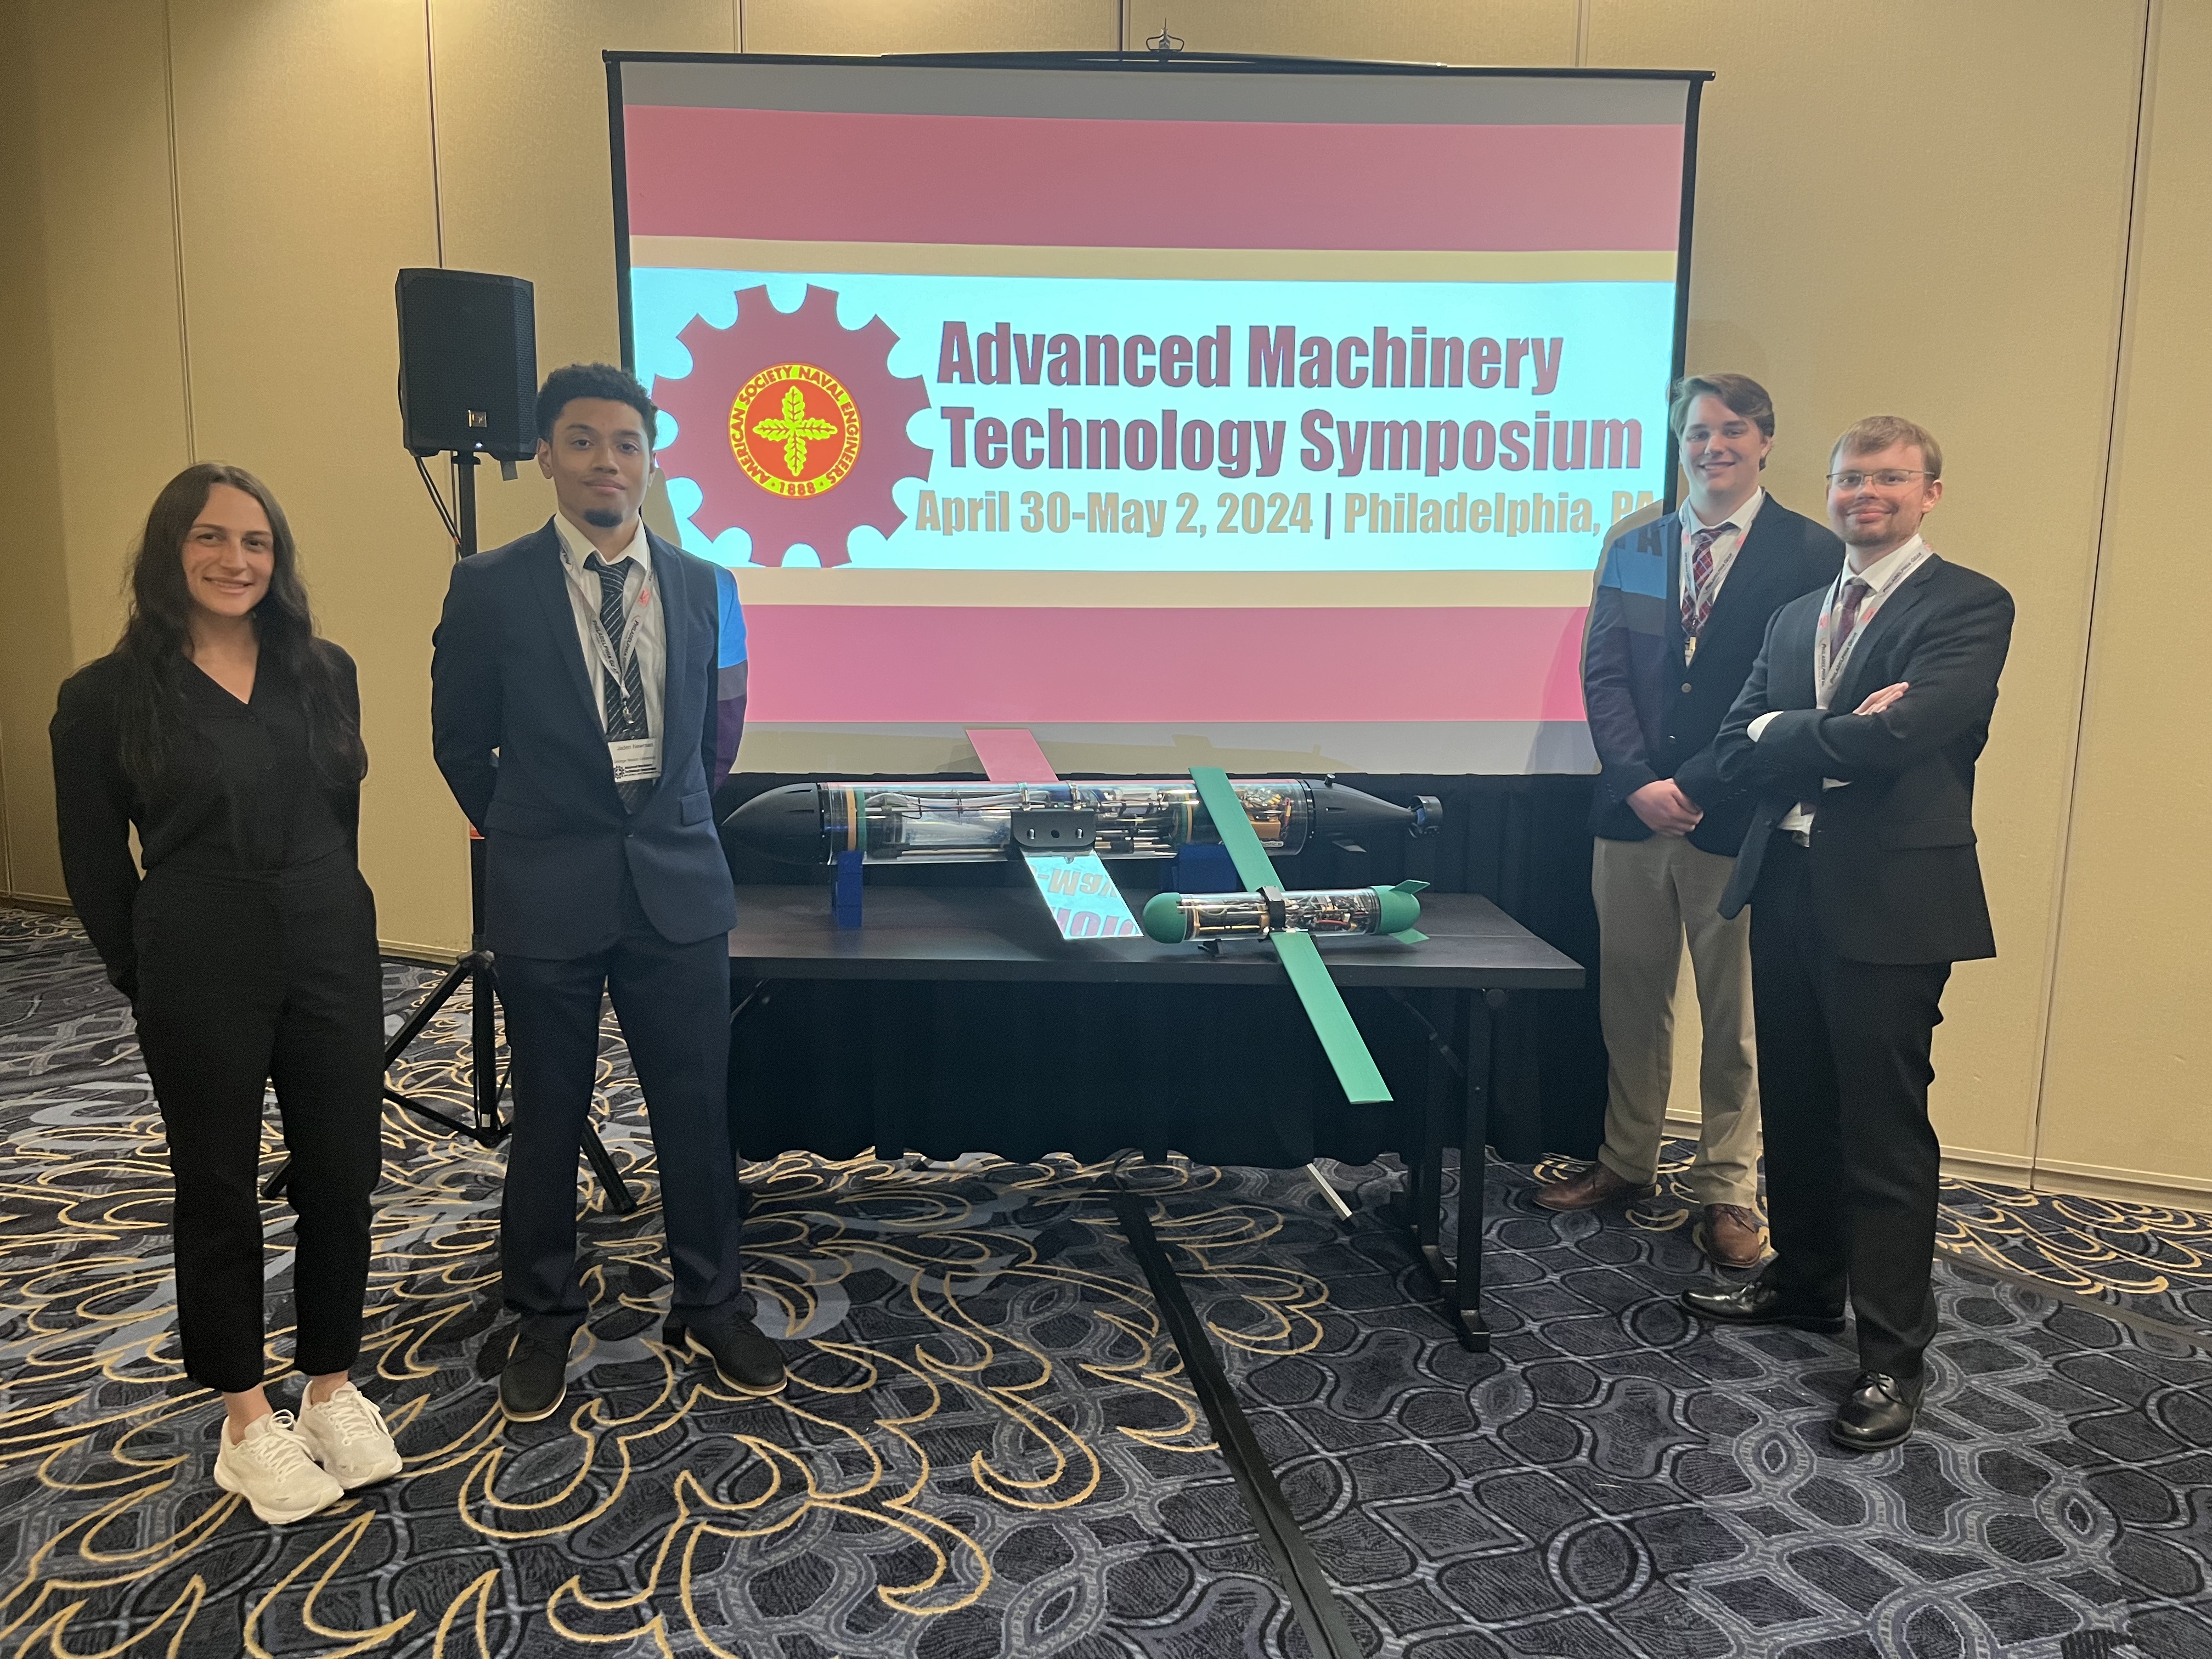
Team JOVE presents at AMTS 2024
It was wonderful to see this excellent group of seniors presenting their capstone design project at the American Society of Naval Engineers’ Advanced Machinery Technology Symposium 2024. A particular highlight was their show-and-tell session with students participating in a STEM event held in conjunction with the conference!

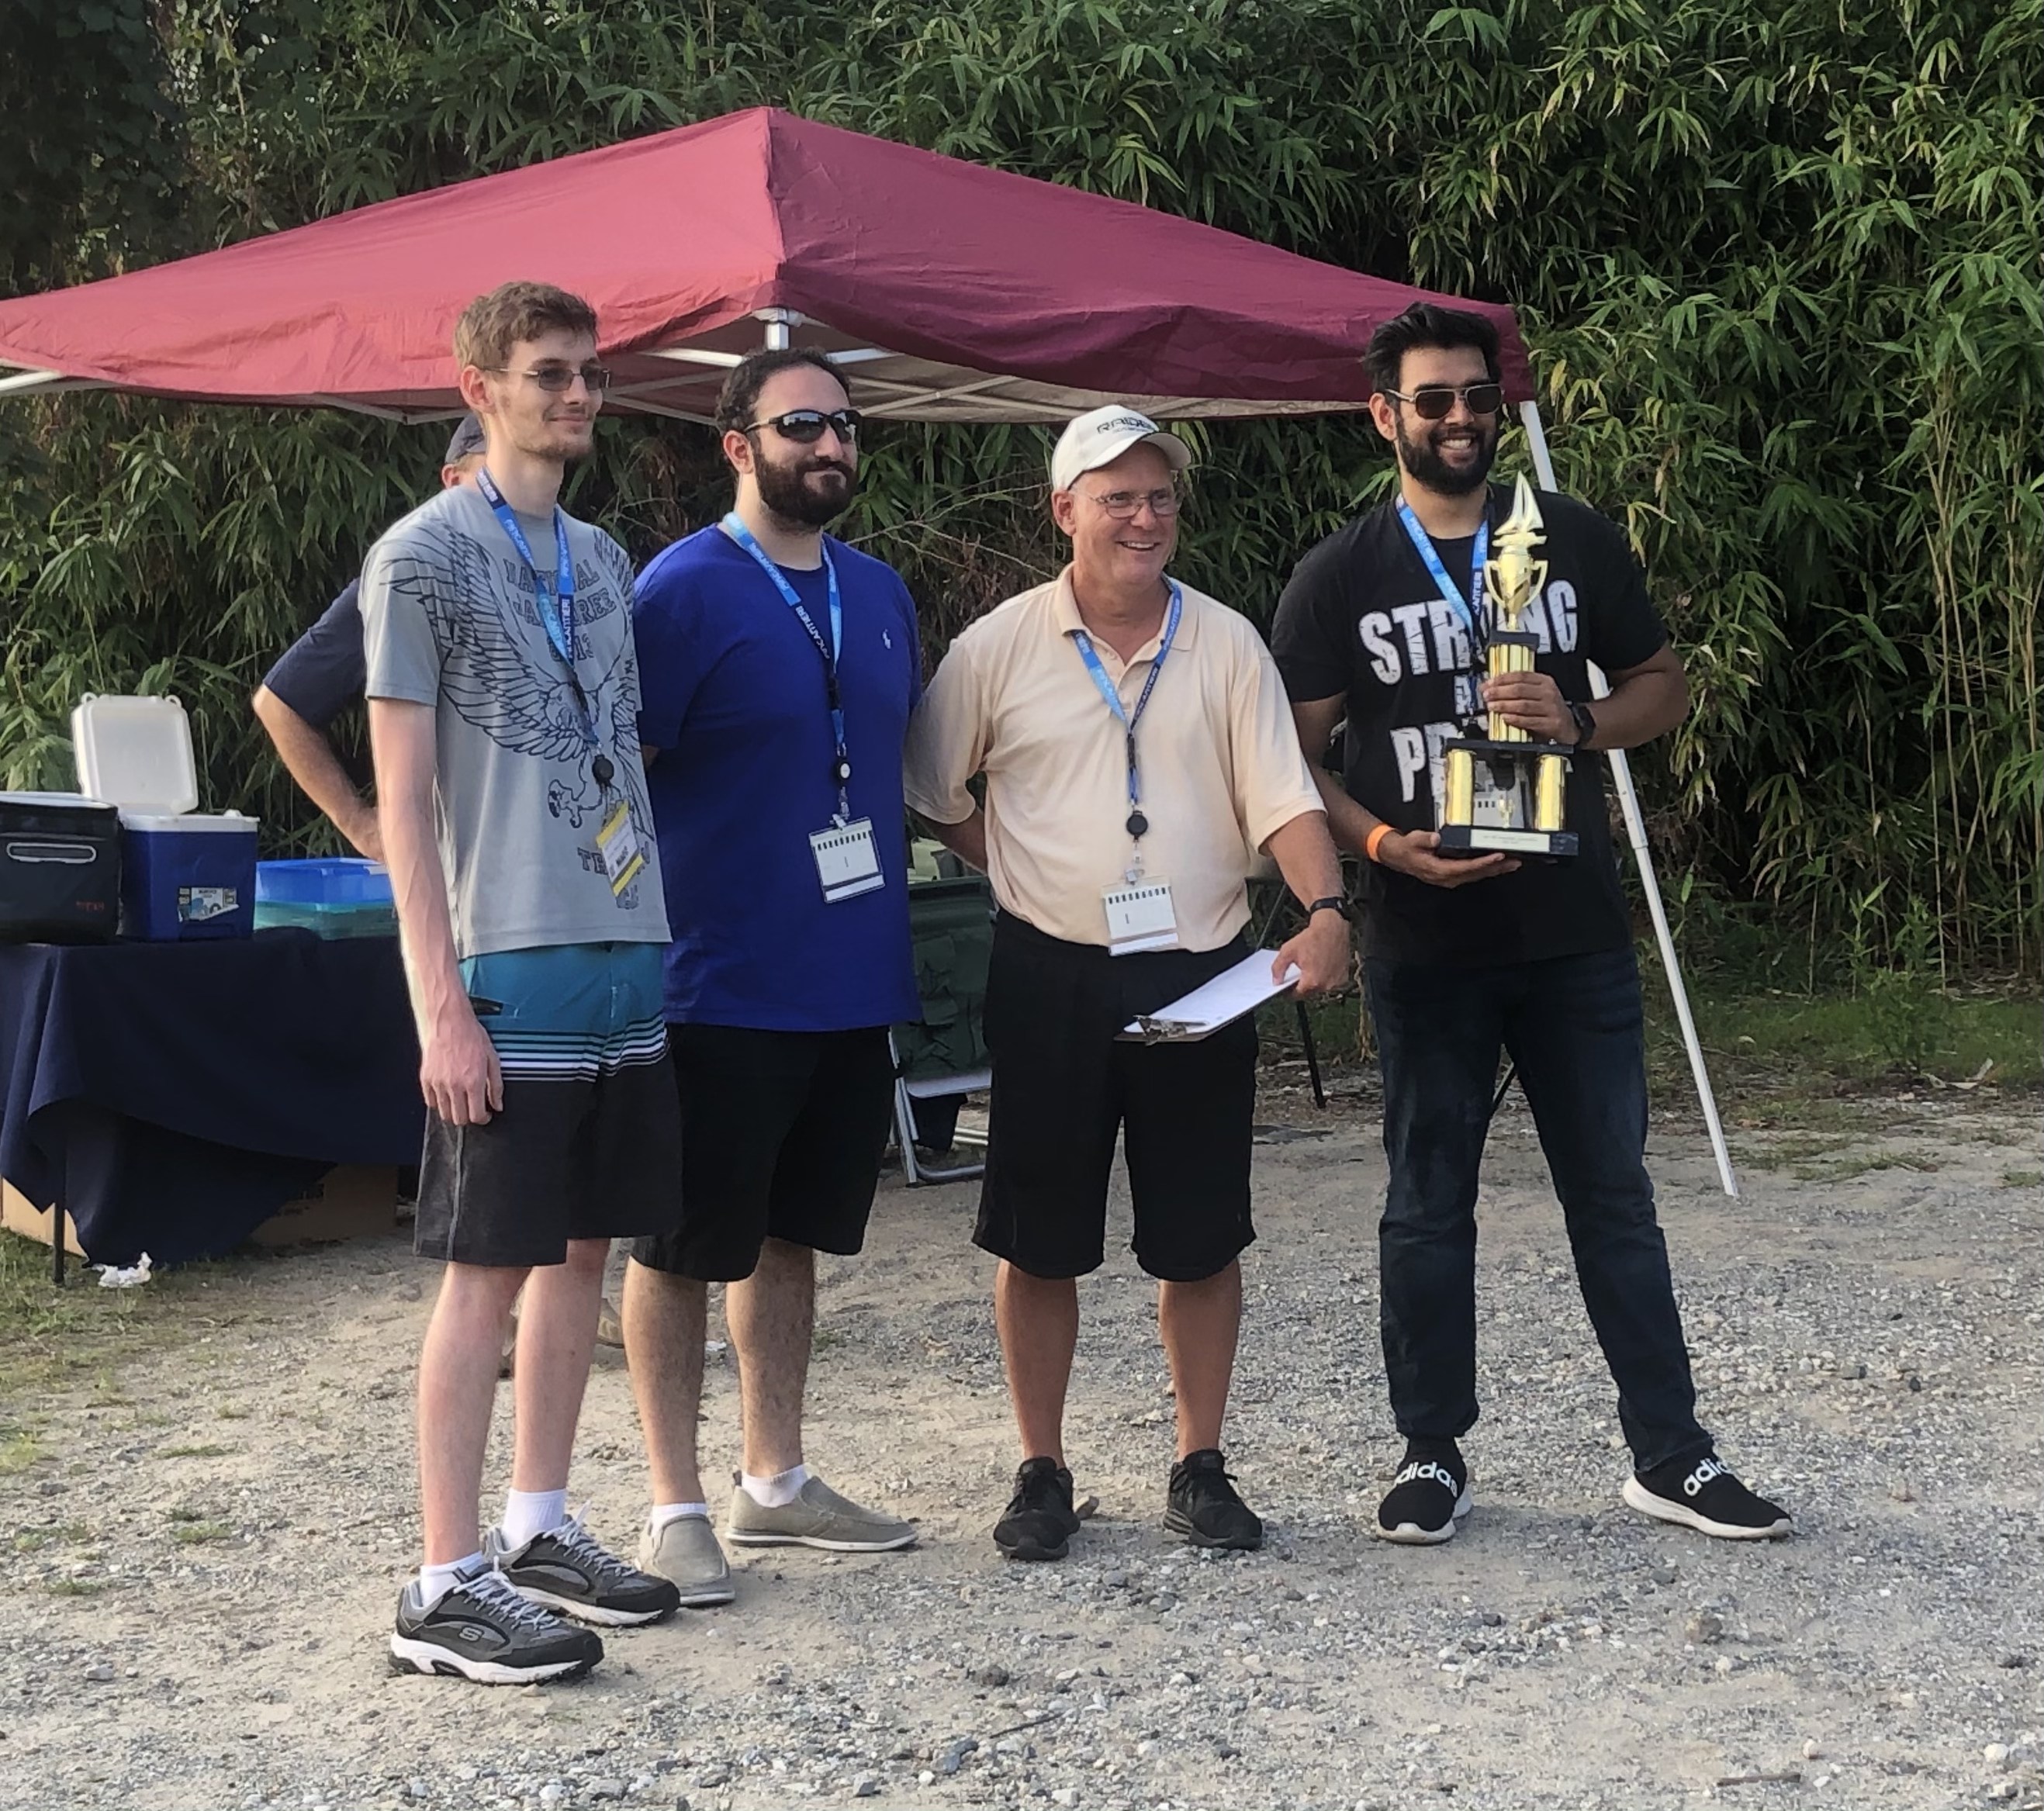
Vessel Dynamics Lab at IEEE/MTS Oceans 2023
The Vessel Dynamics Lab had a fabulous time at IEEE/MTS Oceans 2023 in Limerick, Ireland, where graduate student researcher Vanessa Barth presented on “Gaze controlled underwater remotely operated vehicle (ROV) to improve accessibility in maritime robotics” and undergrad researcher Sam Athapaththu presented his “Autonomous modular water collection system.”

Autonomous modular water collection system
Athapaththu, A., Barth, V., Jones, V., and McCue, L., “Autonomous modular water collection system,” 2023 IEEE Oceans Conference, June 5-8, Limerick, Ireland.
Gaze controlled underwater remotely operated vehicle (ROV) to improve accessibility in maritime robotics
Barth, V., Jones, V., Athapaththu, A., and McCue, L., “Gaze controlled underwater remotely operated vehicle (ROV) to improve accessibility in maritime robotics,” 2023 IEEE Oceans Conference, June 5-8, Limerick, Ireland.
On the vertical and horizontal integration of robotics within engineering and computing education
Barth, V., Berg, C., Costa, P., Cummings, M., Denham, W., Handler, R., Hayes, M., Karri, D., Kathir, N., McCue, L., Miller Hooks, E., Nowzari, C., Reagle, C., Rosenblum, D., Rostobaya, V., Sanders, Q., Shishika, D., Shortle, J., and Sinanovic, E., “On the vertical and horizontal integration of robotics within engineering and computing education,” IUTAM Symposium on Optimal Guidance and Control for Autonomous Systems, March 15-17, 2023, Honolulu, Hawaii.
On the use of video in support of a maritime robotics STEM outreach program
McCue, L., Rathbun, S., Raz, A., Shishika, D., Smith, C., Hagarty, A., Wood, R., Williams, E., Nowzari, C., and Yang, J., “On the use of video in support of a maritime robotics STEM outreach program,” ASEE Southeastern Section Conference, Fairfax, VA, March 12-14, 2023.
SeaPerch and SeaGlide Camp Implementation
McCue, L., Barth, V., and Hall, J., “SeaPerch and SeaGlide Camp Implementation,” ASEE Southeastern Section Conference, Fairfax, VA, March 12-14, 2023.
A Pandemic Pivot Podcast
McCue, L., “A Pandemic Pivot Podcast,” ASEE Southeastern Section Conference, Fairfax, VA, March 12-14, 2023.
Work-in-Progress: Development of a new hands-on STEM program for biologically inspired maritime robotics
McCue, L., Hagarty, A., Nowzari, C., Raz, A., Riggi, M., Rosenberg, J., Shishika, D., Smith, C., Nelson, J., “Work-in-Progress: Development of a new hands-on STEM program for biologically inspired maritime robotics,” Ocean and Marine Engineering Division, American Society for Engineering Education Annual Conference, Minneapolis, MN, June, 2022.
Operational measures for intact ship stability
Shigunov, Vladimir; Themelis, Nikos; Bačkalov, Igor; Begovic, Ermina; Boulougouris, Evangelos; Cichowicz, Jakub; Eliopoulou, Eleftheria; Hashimoto, Hirotada; Hinz, Tomasz; González, Marcos Míguez; Karolius, Kristian; Manderbacka, Teemu; McCue, Leigh; Rodríguez, Claudio, “Operational measures for intact ship stability,” First International Conference on the Stability and Safety of Ships and Ocean Vehicles, June 2021.
A case study on the practical use of low-fidelity modeling to mitigate the spread of COVID-19 amongst the underserved farmworker community
McCue, L., Knight, M., Driscoll, M., Jenkins, P., and Sorensen, J., “A case study on the practical use of low-fidelity modeling to mitigate the spread of COVID-19 amongst the underserved farmworker community,” La Matematica, 2023, https://doi.org/10.1007/s44007-023-00043-4
Field-test of two mobile apps for commercial fishing safety: feedback from fishing vessel captains
Bulzacchelli, M., Bellantoni, J., McCue, L., and Dzugan, J., “Field-test of two mobile apps for commercial fishing safety: feedback from fishing vessel captains,” WORK: A Journal of Prevention, Assessment & Rehabilitation, 2023, doi: 10.3233/WOR-211454
The receptivity to safety-related mobile apps among commercial fishing captains: descriptive exploratory study
Bulzacchelli, M., Bellantoni, J., McCue, L., and Dzugan, J., “The receptivity to safety-related mobile apps among commercial fishing captains: descriptive exploratory study,” JMIR Formative Research, Vol 6, Issue 11, 2022, https://formative.jmir.org/2022/11/e33638.
Buoy Team – Autonomous Mini-Flip Ship
Capstone Team Buoy for the 2022-2023 academic year worked to prototype a (currently) remote controlled (aiming for autonomous) miniature version of the FLIP ship. Here is a brief example of sea trials in the horizontal configuration.
Team Poseidon – Sprint Capable Underwater Glider
One of our 2022-2023 capstone projects was the design and build of a sprint capable underwater glider. Check out their video here.
Demonstrating eye gaze control for a BlueROV2
The paper is in progress, but here’s a sneak peak at Vanessa Barth’s work on eye gaze control using a BlueROV2 as the test platform. From the ROV’s eye-view through the window in the water tank, Vanessa can be spotted facing her computer around 28 seconds in.
RobotX 2022 Wrap-Up email
Friends,
Thank you all sincerely for your role in getting Mason to the 2022 RobotX competition in Penrith, Australia. Our travel team consisted of six individuals – three undergrads: Emina Sinanovic, Damion Colgrove, and Orion Colgrove, one grad student: Vanessa Barth, one alum: Reginald Lockhart, and me. Due to global shipping challenges, we made a tactical decision a couple months out not to ship the boat, and to participate technically as a “documentation only” team. That said, RoboNation generously provided us on-site workspace, and we traveled with our UAV and sensing packages, joining a team of teams with Lake Superior State University and Queensland University of Technology. Mason was able to tick off two competition tasks – the heartbeat message and UAV search and rescue. It was exciting to see the onsite team work, as lead Reggie kept everyone on task, optimistic, and enthusiastic while rapidly tapping into resources from last year’s work, Emina and Vanessa rallied to make the heartbeat happen, and Orion and Damion successfully executed UAV waypoint navigation and perception, all supported by the months of effort students and alums put into the project over the last year, plus wonderful camaraderie from all on-site teams, particularly our LSSU/QUT newfound friends.
Over the course of the last year, we engaged 26 students from mechanical engineering, electrical and computer engineering, computer science, and systems engineering and operations research in this maritime robotics opportunity. This was made possible by amazing faculty mentors from each of those departments: Greg Stein, Jana Kosecka, Lance Sherry, Ali Raz, Erion Plaku, Daigo Shishika, Cameron Nowzari, and Nathan Kathir who oversees the ME department’s capstone program, industry sponsors Gibbs & Cox, Beck Foundation, and the US Government, our volunteer “customer” and source of RobotX knowledge extraordinaire CAPT Dave Edwards, and the stupendous Mason support we received including, but not limited to, Ardiana Brahja for purchasing, Johnnie Hall with prototyping and machining, Melissa Perez and Zachary Machuga on export compliance and shipping, and Kim Goodwin-Slater and Kayla Hine on finance.
Julianna Smith and the whole team at RoboNation and Kelly Cooper at ONR – thank you so much for this opportunity and rolling with us when we made our tactical shift. Travis Moscicki, thank you for your patience and coaching on the heartbeat. Justin Hechinger at Camzilla, thank you for making sure our drone would have power once we got to Australia. To the volunteers from the Model Aeronautical Association of Australia – thank you for keeping things safe and lively. And to the best volunteer embedded judge a team could ask for – Julie Young, big thanks for your wisdom, positivity, and reminders to take lots of photos and enjoy the experience. On the topic of photos, attached are two of my favorites – the Mason team on site and the LSSU/QUT/Mason megateam.
Thank you all, and looking forward to 2024!
Respectfully,
Leigh


RobotX Video
The RoboNation’s 2022 RobotX competition is about a month away! Here’s a video showcasing our travel team.
Samuel Athapaththu
Samuel Athapaththu is an undergrad at Mason starting his senior year this fall in Mechanical Engineering. He is currently working as a research assistant studying ways to acquire water samples on autonomous underwater vehicles. He enjoys building and designing solutions to challenging problems, and in his free time enjoys working out, spending time with family and friends, and exploring new places.

The Mason Mechanical Engineer
Check out podcast episode 6 of The Mason Mechanical Engineer which includes conversations with RobotX team members!
Vanessa Barth
Vanessa joined the Vessel Dynamics Lab as a PhD student in Spring 2022. She received her Bachelor’s degree in Mechanical Engineering from George Mason University, where she loved the environment so much she decided to stay for graduate school. Her research interests include autonomous systems, dynamics and controls, and machine learning. She is currently working on accessible control of an ROV using an eye tracker. Outside the lab, Vanessa enjoys cooking, solving jigsaw puzzles, and playing with her dogs.

Understanding Quantum Technologies
The latest episode of The Mason Mechanical Engineer podcast is out, featuring a conversation with Pilgyu Kang and Patrick Vora talking about quantum science, engineering, and computing. Check it out on your podcast platform of choice or at: https://anchor.fm/mason-meche/episodes/You-are-not-an-atom-e1cs41f.

WAM-V
We are fielding a team for the 2022 RobotX challenge! So very excited after the first assembly of our WAM-V a few weeks ago. Exciting things on the horizon in maritime robotics at Mason!
The Mason Mechanical Engineer
My department has launched a podcast! The first few episodes are out, with the latest including interviews with a very inspirational Mason alum Jazzmin Robinson as well as NAWCAD’s Director of Engineering Education and Research Partnerships Theresa Shafer. Search for the “Mason Mechanical Engineer” on your preferred podcast platform or click here.

Mason PEP Team Takes 2nd Place in Unmanned Category of Electric Boat Competition
Congratulations to the Mason PEP team on their 2nd place finish in the “unmanned” category of ASNE’s Promoting Electric Propulsion competition held at the 2021 Multi-Agency Craft Conference (MACC). This represented the culmination of three senior design team’s efforts – a hull team and propulsion team in the 2019-2020 academic year, and a holistic team to pull it all together in the 2020-2021 academic year. Despite pandemic, these students’ hard work paid off the minute their boat entered the water. Proud of y’all. Well done!


Undergrad researcher Cheryl Blanchard wraps up commercial fishing sleep monitoring device prototyping effort
Cheryl did great work during the Spring term of 2021 looking at developing a purpose-built device to measure sleep aboard a fishing vessel, taking into consideration constraints we’ve seen with commercial off the shelf devices. Check out her presentation at: https://celebration.oscar.gmu.edu/development-of-a-prototype-sleep-monitoring-device-for-use-in-the-commercial-fishing-environment/.
A Low-Fidelity Stochastic Model of Viral Spread in Aircraft to Assess Risk Mitigation Strategies
McCue, L, “A Low-Fidelity Stochastic Model of Viral Spread in Aircraft to Assess Risk Mitigation Strategies,” ASME. ASME J. Risk Uncertainty Part B. Available online February 4, 2021.

Team Leviathan – Open Water Testing
Mason’s Team Leviathan had a successful first day of open water testing in advance of the 2021 Promoting Electric Propulsion (PEP) competition!
Vessel Dynamics Lab Growing – Now Seeking Post-Doc
The Vessel Dynamics Laboratory is looking to add a post-doctoral researcher to the team. The ideal candidate would have expertise in agent based modeling and/or smoothed particle hydrodynamics (SPH), past work experience with human subjects, and an enthusiasm for occupational safety research. If this sounds like you or someone you know, please contact Leigh!
Low cost unmanned surface vehicle swarm formation control using a potential field
Bhanderi, D. and McCue, L., “Low cost unmanned surface vehicle swarm formation control using a potential field,” Global OCEANS 2020: Singapore-U.S. Gulf Coast, October 2020.
CDR Brook Sherman becomes Commanding Officer USCG Base Elizabeth City
Congratulations to Vessel Dynamics lab alum Brook Sherman – USCG Base Elizabeth City is in good hands!
A coupled SPH-FEM Solver for Modeling Surface Effect Ship (SES) Bow Seal Dynamics
Gilbert, J. and McCue, L., “A coupled SPH-FEM Solver for Modeling Surface Effect Ship (SES) Bow Seal Dynamics,” Virtual 39th International Conference on Ocean, Offshore & Arctic Engineering (OMAE) 2020, June 28-July 3, 2020.
The Portia Hypothesis: Mechanical Engineering Student Perceptions of Qualifications
McCue, L., “The Portia Hypothesis: Mechanical Engineering Student Perceptions of Qualifications,” Virtual American Society of Engineering Education Annual Conference, June 2020.
Farmworker housing simulator website live
Interested in understanding how COVID-19 can spread on farms? Check out the farmworker housing simulator!
And thank you to the Volgenau School of Engineering News for this nice writeup: https://volgenau.gmu.edu/news/584946
Vessel Dynamics Lab Alum Rosa Avalos-Warren in the News
Vessel Dynamics Lab alum Rosa Avalos-Warren is making news for her support of the SpaceX Crew Dragon launch. Check out NASA Goddard’s website to read the full story! So proud of you Rosa!
Dhawal Bhanderi 3d printing PPE
Check out this great article about Dhawal Bhanderi’s work to help supply Hampton Roads hospitals with PPE: https://volgenau.gmu.edu/news/584831

Autonomous running of the Vessel Dynamics Lab’s Mako
This is an RC to autonomous conversion done by undergraduate researcher Dhawal Bhanderi. In this video, at 4x speed, it starts off running autonomously, Dhawal takes control as it goes under the dock, then returns it to autonomous waypoint tracking. Check out the video: